Archives

  • Biomarker may clear up how depression saps motivation
  • Play Video

    Chameleons’ weird speedy tongues inspire faster soft robots

    (Credit: Getty Images)

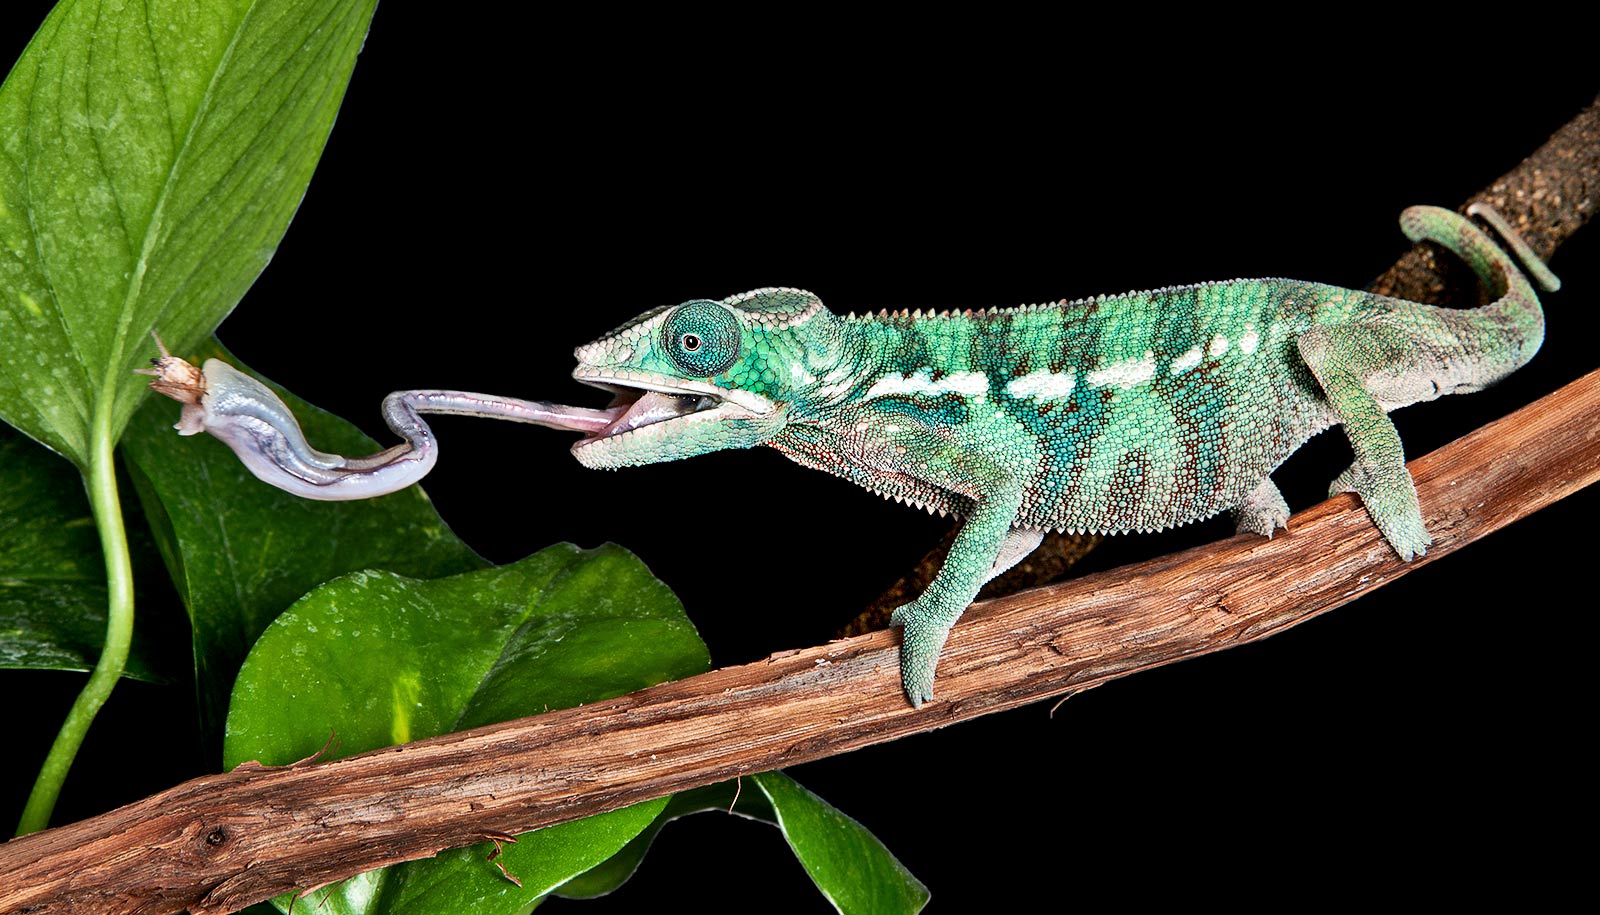
    Getting inspiration from a chameleon’s tongue, researchers have created soft robots that can recreate high-powered and high-speed motions using stored elastic energy.

    Chameleons, salamanders, and many toads use stored elastic energy to launch their sticky tongues at unsuspecting insects located up to one-and-a-half body lengths away, catching them within a tenth of a second.

    The researchers made the robots using stretchable polymers similar to rubber bands, with internal pneumatic channels that expand upon pressurization. To store the elastic energy, the robots stretch their body in one or multiple directions during the fabrication process following nature-inspired principles.

    Similar to the chameleon’s tongue strike, a pre-stressed pneumatic soft robot can expand five times its own length, catch a live fly beetle, and retrieve it in just 120 milliseconds.

    “We believed that if we could fabricate robots capable of performing such large-amplitude motions at high speed like chameleons, then many automated tasks could be completed more accurately and in a much faster way,” says Ramses Martinez, an assistant professor in the School of Industrial Engineering and in the Weldon School of Biomedical Engineering at Purdue University.

    “Conventional robots are usually built using hard and heavy components that slow down their motion due to inertia. We wanted to overcome that challenge.”

    Reacts in 50 milliseconds

    Many birds, like the three-toed woodpecker, achieve zero-power perching using the elastic energy stored in the stressed tendons at the back of their legs, allowing them to not fall off a perch when asleep.

    The anatomy of these birds has served as an example to enable the fabrication of robotic grippers capable of zero power holding up to 100 times their weight and perching upside down from angles of up to 116 degrees.

    This video shows how these bird-inspired soft robotic gripper catching a ball moving at 10 millimeters per second in only 65 milliseconds:

    The conformability of the soft arms of these grippers to the gripped object maximizes contact area, enhancing grasping and facilitating high-speed catching and zero-power holding.

    This video shows how these grippers can perch upside down from angles up to 116 degrees:

    Some plants also know how to exploit elastic energy to achieve high-speed motion using “trap mechanisms.” The Venus flytrap uses the elastic energy stored in its bistable, curved leaves to rapidly close on prey exploring their inner surface.

    This high-speed camera video shows the closure in a snap of this soft robotic Venus flytrap:

    Inspired by the trap mechanism of the Venus flytrap and studying how lizards catch insects, researchers created a soft robotic Venus flytrap, which closes in only 50 milliseconds after receiving a short pressurized stimulus.

    Super speeds

    These new pre-stressed soft robots have several significant advantages over existing soft robotic systems, Martinez says. First, they excel at gripping, holding, and manipulating a large variety of objects at high speed. They can use the elastic energy stored in their pre-stressed elastomeric layer to hold objects up to 100 times their weight without consuming any external power.

    Researchers can easily pattern their soft skin with anti-slip microspikes, which significantly increases their traction and allows them to perch upside down over prolonged periods of time and facilitates the capture of live prey.

    “We envision that the design and fabrication strategies proposed here will pave the way toward a new generation of entirely soft robots capable of harnessing elastic energy to achieve speeds and motions currently inaccessible for existing robots,” Martinez says.

    The paper appears in Advanced Functional Materials. Martinez and his team have worked with the Purdue Research Foundation Office of Technology Commercialization to patent some of his technologies related to robots and other design innovations.

    Source: Purdue University
    Play Video

    How birds perch could lead to nimbler flying robots

    (Credit: Getty Images)

    The way birds can successfully perch on the Teflon and other materials is teaching researchers how they might create flying robots that land like a bird.

    Under the watchful eyes of five high-speed cameras, a small, pale-blue bird named Gary waits for the signal to fly. Diana Chin, a graduate student at Stanford University and Gary’s trainer, points her finger to a perch about 20 inches away. The catch here is that the perch is covered in Teflon, making it seemingly impossible to stably grasp.

    Gary’s successful touchdown could help researcher build better flying robots.

    “Modern aerial robots usually need either a runway or a flat surface for easy takeoff and landing. For a bird, almost everywhere is a potential landing spot, even in cities,” says Chin, part of the lab of David Lentink, assistant professor of mechanical engineering. “We really wanted to understand how they accomplish that and the dynamics and forces that are involved.”

    Stick the landing

    Even the most advanced robots come nowhere near the grasping ability of animals when dealing with objects of varying shapes, sizes, and textures. So, the researchers gathered data about how Gary and two other birds land on different kinds of surfaces, including a variety of natural perches and artificial perches covered in foam, sandpaper, and Teflon.

    “This is not unlike asking an Olympic gymnast to land on Teflon-covered high bars without chalking their hands,” says Lentink, senior author of the paper in eLife. Yet, the parrotlets made what seems almost impossible for a human look effortless.

    The findings also include detailed studies of how the birds’ claws and feet produce friction. From this work, the researchers found that the secret to the parrotlet’s perching versatility is in the grip.

    “When we look at a person running, a squirrel jumping, or a bird flying, it is clear that we have a long way to go before our technology can reach the complex potential of these animals, both in terms of efficiency and controlled athleticism,” says William Roderick, a graduate student in mechanical engineering in the Lentink lab and in the lab of Mark Cutkosky, chair in the School of Engineering.

    “Through studying natural systems that have evolved over millions of years, we can make tremendous strides toward constructing systems with unprecedented capabilities.”

    It’s all in the grip

    The perches researchers used in the study aren’t your average pet store stock. The researchers split them in two, lengthwise, at the point that approximately aligned with the center of a parrotlet’s foot. As far as the bird was concerned, the perches felt like a single branch but each half sat atop its own 6-axis force/torque sensor.

    This meant the researchers could capture the total forces the bird put on the perch in many directions and how those forces differed between the halves—which indicated how hard the birds were squeezing.

    After the birds flapped to all nine force-sensing perches of assorted size, softness, and slipperiness, the group began analyzing the first stages of landing. Comparing different perch surfaces, they expected to see differences in how the birds approached the perch and the force with which they landed, but that’s not what they found.

    “When we first processed all of our data on approach speed and the forces when the bird was landing, we didn’t see any obvious differences,” Chin says. “But then we started to look into kinematics of the feet and claws—the details of how they moved those—and discovered they adapt them to stick the landing.”

    The extent to which the birds wrapped their toes and curled their claws varied depending on what they encountered upon landing. On rough or squishy surfaces—such as the medium-size foam, sandpaper, and rough wood perches—their feet could generate high squeeze forces with little help from their claws.

    On perches that were hardest to grasp—the floss-silk wood, Teflon, and large birch—the birds curled their claws more, dragging them along the perch surface until they had secure footing.

    This variable grip suggests that, when building robots to land on a variety of surfaces, researchers could separate the control of approaching landing from the actions required for a successful touchdown.

    Their measurements also showed that the birds can reposition their claws from one graspable bump or pit to another in a mere 1 to 2 milliseconds. (For comparison, it takes a human about 100 to 400 milliseconds to blink.)

    Flying robots taking off

    The researchers have already begun characterizing how parrotlets take off from the different surfaces. Combined with their previous work exploring how parrotlets navigate their environment, the group hopes the findings can lead to more nimble flying robots.

    “If we can apply all that we learn, we can develop bimodal robots that can transition to and from the air in a wide range of different environments and increase the versatility of aerial robots that we have today,” Chin says.

    Toward that end, Roderick is working on designing the mechanisms that would mimic the birds’ gripping form and physics.

    “One application of this work that I’m interested in is having perching robots that can act as a team of tiny little scientists that make recordings, autonomously, for field research in forests or jungles,” he says.

    “I really enjoy drawing from the fundamentals of engineering and applying them to new fields to push the limits of what has been previously achieved and what is known.”

    The National Science Foundation, the Air Force Office of Scientific Research, the Department of Mechanical Engineering at Stanford, and the Department of Defense funded the work.

    Source: Stanford University