Archives

Play Video

Watch this little robot hop and swim like a frog

An illustration of the hopping robot shows the elastic rods bent into loops at the rear. When the bent rods are twisted, they suddenly snap, producing a hopping motion reminiscent of a frog. (Credit: Dezhong Tong, University of Michigan/UCLA)

The twisting of bent elastic rods can produce a snapping motion that enables small robots to hop or swim, researchers have shown.

The advance offers a promising mechanism for robots with limited power, particularly miniature robots, according to the research team.

Published in Science Advances, the research was co-led by Khalid Jawed, an associate professor of mechanical and aerospace engineering at UCLA, and Xiaonan (Sean) Huang, an assistant professor of robotics the University of Michigan.

“The broader opportunity is to let the mechanics of the robot do some of the work that would otherwise require larger motors or more complicated control,” Huang says.

“By programming when an elastic structure stores and rapidly releases energy, we can give small robots access to powerful, repeatable motions without continuously demanding high output from the motor. In the future, this principle could be useful for robots that must navigate cluttered terrain, overcome obstacles, reorient quickly, or operate across both land and water.”

Perfecting the snap

When a flexible rod is bent, and its ends are rotated, it eventually reaches a point where it changes shape to release built-up tension—but this change does not always happen in the same way. Under some combinations of bending and twisting, the rod changes shape gradually. Under others, it snaps rapidly from one shape to another, with the potential to provide a strong push.

Through computer modeling and experiments, the team optimized a helical shape, like a segment of a coiled spring, that maximized the burst of energy while resetting quickly for the next snap.

“Because it’s the rod’s shape—not its size—that determines whether it snaps sharply or deforms gradually, the same design rules apply across a wide range of scales,” says Jawed, whose lab worked on the simulation and robot arm experiments.

“This opens a promising path toward robots just a few millimeters wide, turning small motor movements into powerful bursts of motion.”

Testing snap propulsion in a robot

After optimizing the propulsion mechanism, the team designed and built real robots that use the snapping rods to hop. Connected to a rotating motor, the bent rods twist until they produce the snapping motion. Then the motor unwinds the twist and proceeds to contort the rod again.

“Once we could predict when a rod would snap, we could use that sudden release of energy to turn a simple motor movement into a powerful push that sends the robot hopping forward,” says UM postdoctoral scholar Dezhong Tong, the study’s co-lead author with Jiaqi Wang, a PhD student in robotics at UM. Tong started working on the project while a graduate student in Jawed’s group at UCLA.

The frog-like prototype, with a pair of snapping rods at the rear of the device, hopped over a broad range of test surfaces—from solid materials like wood and glass to soft and slippery materials like leather. Outside, the palm-sized robot tackled sand and grass. It could climb and descend steps and, with paddle attachments, could even swim.

Moving the two snapping rods at different rates enabled the robot to turn, and the team used a remote control to maneuver the robot around a small sandbox with rock obstacles. They also automated a simple navigation method, using light sensors so that the robot would approach a light source.

The small prototype, weighing about 0.25 lbs, could move about three body lengths per second—similar to a baby loggerhead turtle making its way to the sea.

Additional study authors are from the University of Michigan; Vassar College in New York; and Newcastle University, UK.

The study was funded by the National Science Foundation.

Source: University of Michigan
  • ‘Dumb’ robot swarm works with no electronics at all
  • Play Video

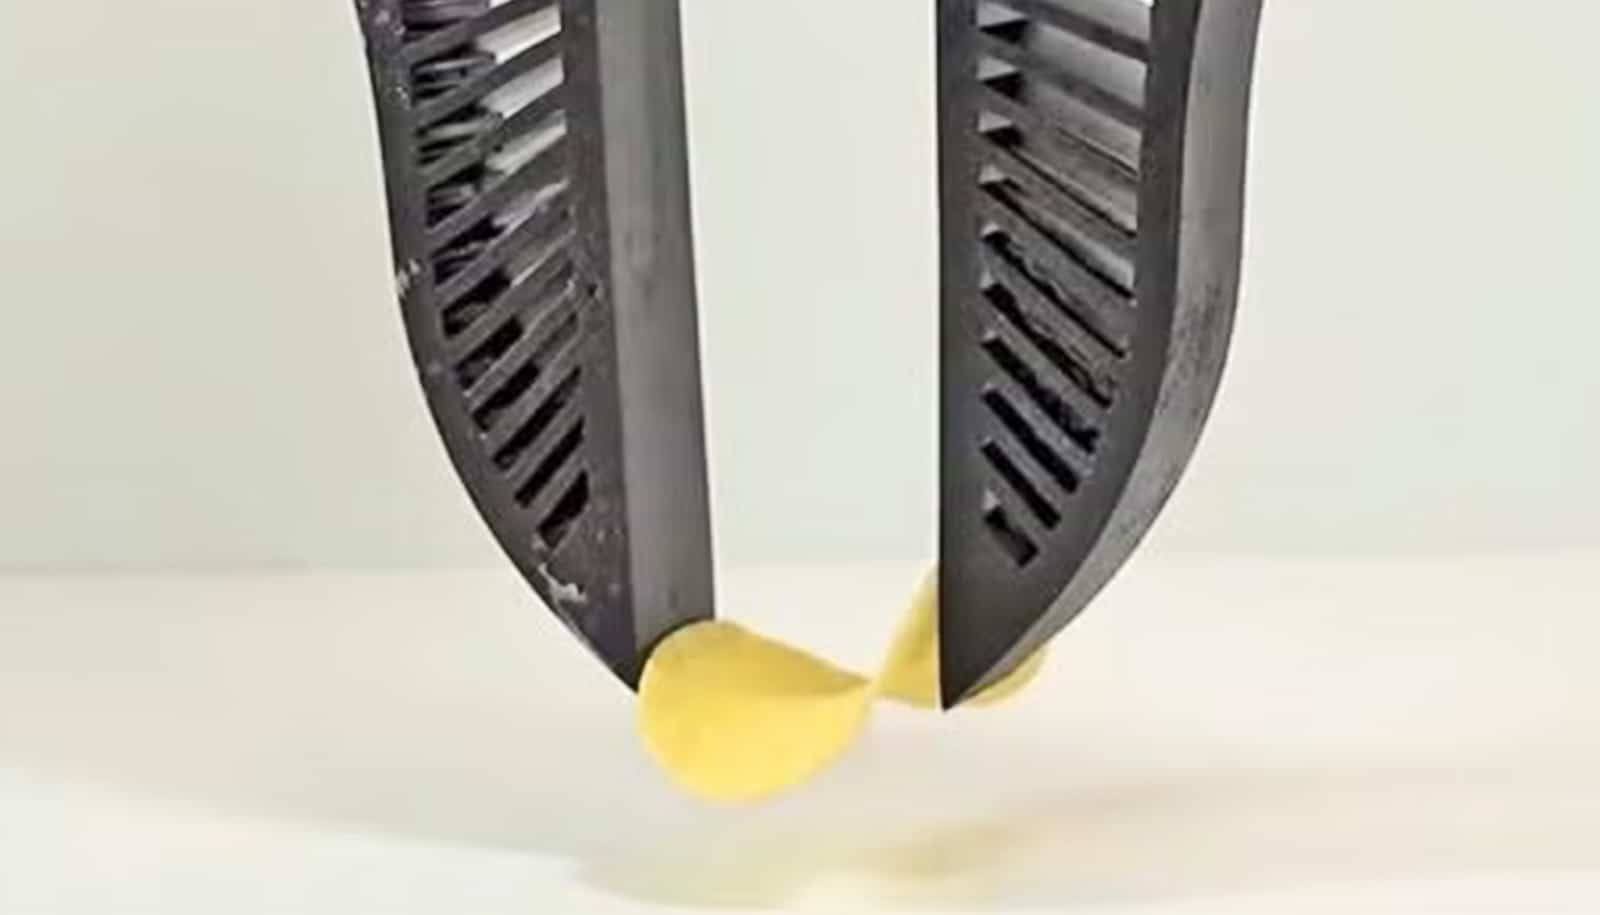
    Watch: This robot hand is sensitive enough to pick up a potato chip

    (Credit: UT Austin)

    A new type of robotic hand developed has such sensitive touch that it can grasp objects as fragile as a potato chip or a raspberry without crushing them.

    The technology, called Fragile Object Grasping with Tactile Sensing (FORTE), combines advanced tactile sensing with soft robotics.

    The breakthrough could improve robot performance when a light touch is needed, such as in health care and manufacturing.

    “Right now, robotics is starting to be able to do large motions around the house, but struggles with really fine and delicate movements,” says Siqi Shang, lead author of a new paper published in IEEE Robotics and Automation Letters and a doctoral student in the the University of Texas at Austin’s Cockrell School of Engineering’s electrical and computer engineering department.

    “Robots can fold a shirt but may struggle to carefully pick up your glasses or unpack fruit from your groceries. We believe sensing signals will give robots a sense of touch to handle these objects carefully.”

    The fingers at the heart of this technology were inspired by the fin-ray effect—a design principle derived from the natural structure of fish fins. These fingers are made using advanced 3D-printing techniques and feature internal, empty air channels that act as tactile sensors. The researchers recently applied the sensing technology to a year-long collaboration with the College of Fine Arts’ theatre and dance department.

    When the fingers prepare to grasp an object, the air channels inside them also shift, causing changes in air pressure. These pressure changes are detected by small, off-the-shelf sensors that provide real-time force feedback to the robot and let it know whether the object is slipping.

    The researchers tested the grippers on 31 objects, including fragile items such as raspberries and potato chips, slippery items such as jam jars and billiard balls, and everyday items such as soup cans and apples.

    The system achieved a 91.9% success rate in single-trial grasping experiments, outperforming traditional grippers that rely solely on visual feedback.

    The system recognized 93% of slips with 100% precision, meaning it never falsely identified a slip event. This high level of precision ensures that the robot adjusts its grip only when necessary, avoiding excessive force that could damage an object.

    “Humans pick up objects with just the right amount of force; too much and you’ll crush it, but too little and it’ll slip out of your hand,” says Lillian Chin, assistant professor of electrical and computer engineering at UT.

    “Most current force sensors aren’t fast or accurate enough to provide that Goldilocks level of detail. In particular, our sensors operate closer to the timescales of human hand sensors.”

    In addition to speed and accuracy, these fingers have a longer lifespan than other devices under development. Because the sensors are 3D printed, they can be easily customized to a variety of shapes.

    The slip-sensing ability is what really distinguishes them. Very few robotic gripping technologies have slip detection at all, and those that do can’t match FORTE’s reaction time and speed.

    FORTE is a significant milestone in the quest to create robot hands with dexterity similar to that of humans, and it could affect many industries:

    • In food processing, where handling fragile items such as fruits, vegetables, and baked goods is a daily challenge, more sensitive machinery could reduce waste and improve efficiency.
    • In health care, robots could handle medical instruments or fragile biological samples with precision.
    • In manufacturing, the technology could be used to handle delicate components, such as electronics or glassware.

    The researchers have publicly released the hardware designs and algorithms to encourage other scientists and engineers to build upon their work. They’re still fine-tuning the technology, and the next steps include making the sensors less sensitive to temperature changes and improving the ability to catch objects that are slipping.

    Support for the research came from the Texas Robotics Industrial Affiliate Program, the National Science Foundation, the Office of Naval Research, the DARPA TIAMAT program, and South Korea’s Institute of Information & Communications Technology Planning & Evaluation.

    Source: UT Austin